Tag Archives: soft robots

‘Brain-free’ robots that move in synchronization, powered entirely by air

This brain-free robot reminds me of a (battery-powered) toy I loved,

A November 18, 2025 University of Oxford press release (a similar version is also on EurekAlert but published November 4, 2025) announces a new type of soft robot, Note: Links have been removed,

A team led by the University of Oxford has developed a new class of soft robots that operate without electronics, motors, or computers – using only air pressure. The study, published today (05 Nov) in Advanced Materials, shows that these ‘fluidic robots’ can generate complex, rhythmic movements and even automatically synchronise their actions.

Professor Antonio Forte (Department of Engineering Science, University of Oxford, Lead of RADLab) said: “We are excited to see that brain-less machines can spontaneously generate complex behaviours, decentralising functional tasks to the peripheries and freeing up resources for more intelligent tasks.”

Overcoming a key challenge in soft robotics

Soft robots (made from flexible materials) are ideal for tasks like navigating uneven terrain or handling delicate objects. A major goal in soft robotics is to encode behaviour and decision-making directly into the robot’s physical structure, enabling more adaptive and responsive machines. This kind of automatic behaviour – emerging from body-environment interactions – is often difficult to replicate with traditional electronic circuits, which require complex sensing, programming and control systems.

To address this challenge, the researchers took inspiration from nature, where body parts often perform multiple roles and synchronised behaviour can emerge without central control. Their key innovation was to develop a small, modular component that uses air pressure to perform mechanical tasks – similar to how an electronic circuit uses electrical current. Depending on how it is set up, this single block can either:

  • Actuate (move or deform) in response to air pressure changes – functioning like a muscle.
  • Sense pressure changes or contact – similar to a touch sensor.
  • Switch air flow between ON/OFF states – like a valve or a logic gate.

Similar to LEGO pieces, multiple identical units (each one a few centimetres in size) can be connected to form different robots without changing the basic hardware design. In the study, the researchers constructed tabletop robots (roughly the size of a shoebox), that could hop, shake, or crawl.

In a particular configuration, the researchers found that each individual unit can automatically combine all three roles at once, enabling it to generate rhythmic movement entirely on its own once constant pressure is applied. When several of these responsive units are linked together, their movements began to synchronize naturally, without any computer control or programming.

These behaviours were used to make a shaker robot (able to sort beads into different containers by tilting a rotating platform) and a crawler robot (which could detect the edge of a table and automatically stop, preventing a fall). In each case, the coordinated movements were achieved entirely mechanically, with no external electronic control.

Lead author Dr Mostafa Mousa (Department of Engineering Science, University of Oxford) said: “This spontaneous coordination requires no predetermined instructions but arises purely from the way the units are coupled to each other and upon their interaction with the environment.”

Laying the groundwork for embodied intelligence

Crucially, the synchronised behaviour is only seen when the robots are linked together and touching the ground. The researchers used a mathematical framework called the Kuramoto model, which describes how networks of oscillators can synchronize, to explain this behaviour.

This revealed that complex, coordinated motion can emerge in the robots purely from their physical design when they are mechanically coupled through the environment. In this case, the motion of each robotic leg subtly affects the others through the shared body and ground reaction forces. This creates a feedback loop where the forces transmitted via friction, compression, and rebound link the motions of the limbs together, leading to spontaneous coordination.

Dr Mousa said: “Just as fireflies can begin flashing in unison after watching one another, the robot’s air-powered limbs also fall into rhythm, but in this case through physical contact with the ground rather than visual cues. This emergent behaviour has previously been observed in nature, and this new study represents a major step forward towards programmable, self-intelligent robots.”

Although the soft robots developed are currently at tabletop scale, according to the researchers the design principles are scale-independent. In the near future, the researchers aim to investigate these dynamical systems to build energy-efficient untethered locomotors. This would be one step forward towards the large-scale deployment of these robots in extreme environments where energy is scarce and adaptability is needed.

Professor Forte added: “Encoding decision-making and behaviour directly into the robot’s physical structure could lead to adaptive, responsive machines that don’t need software to ‘think.’ It is a shift from ‘robots with brains’ to ‘robots that are their own brains.’ That makes them faster, more efficient, and potentially better at interacting with unpredictable environments.”

Here’s a link to and a citation for the paper,

Multifunctional Fluidic Units for Emergent, Responsive Robotic Behaviors by Mostafa Mousa, Alberto Comoretto, Johannes T.B. Overvelde, Antonio E. Forte. Advanced Materials DOI: https://doi.org/10.1002/adma.202510298 First published: 06 November 2025

This paper is open access.

Paracrystalline carbon nanoparticles and morphing soft robots

Michael Berger’s June 19, 2025 Nanowerk spotlight article focuses on a new development where soft robots are concerned, Note: A link has been removed,

The flexibility of living tissue inspires efforts to build robots that are soft, adaptive, and capable of complex movements. Creating such machines is technically demanding, especially when they must operate without physical tethers. Soft robots need materials that deform easily, actuators that respond quickly, and control methods that are both precise and lightweight. Most existing approaches fail to deliver on all three. Magnetic systems require bulky hardware. Light and heat actuation offer wireless control, but struggle with speed and complexity. Electric fields offer a promising alternative—but only if the materials can translate field stimuli into fast, large-scale movement without relying on wires or embedded circuitry.

Traditional electrically responsive gels deform slowly, limited by the movement of ions. Other systems, such as dielectric elastomer actuators, produce stronger and faster responses but rely on internal electrodes or onboard electronics that compromise their softness and range of motion. To make electric-field actuation practical for untethered soft robots, materials must respond quickly, deform extensively, and be controlled entirely from the outside. Advances in soft polymers and conductive nanomaterials have opened the door to this possibility.

A study published in Advanced Materials (“Electric Field Driven Soft Morphing Matter”) reports a material system that meets these criteria. Developed by researchers at the University of Bristol and Imperial College London, the material—called electro-morphing gel, or e-MG—combines a soft elastomer, a dielectric liquid, and paracrystalline carbon nanoparticles. When exposed to externally applied electric fields, e-MG exhibits fast, large, and reversible shape changes. These include stretching, twisting, bending, and locomotion. All movements are controlled wirelessly through low-cost external electrodes.

Demonstration of the deformability of e-MG robots. a) Illustration of the e-MG material structure and its principle of actuation under an electric field. b) Conceptual diagram showcasing the potential of e-MG robots in space applications. c) An e-MG gymnast swinging along a ceiling. d) An e-MG snail jumping over a gap. e) An e-MG robot delivering cargo through a channel. Demonstrations in (c–e) were performed in a dielectric liquid environment. Scale bars are 5 mm. Courtesy: Authors and Advanced Materials [downloaded from https://advanced.onlinelibrary.wiley.com/doi/10.1002/adma.202419077]

Berger describes the new material, electro-morphing gel (e-MG), in more detail,

At the heart of e-MG’s performance is its material composition. The elastomer provides structural flexibility, while the dielectric liquid softens the matrix and adjusts its electrical properties. The carbon particles, just tens of nanometers wide, introduce mobile charges. When the concentration of carbon exceeds a critical level—between 0.1 and 0.5 percent by weight—these particles form continuous paths for charge transport. The result is a percolated, electrically responsive gel that deforms rapidly in response to non-uniform electric fields.

The material responds to two physical mechanisms: electrostatic and dielectrophoretic forces. Electrostatic force acts on charges within the gel, pushing it in the direction of the field. Dielectrophoretic force acts on polarized material in a gradient field, pulling it toward stronger regions. When both forces align, the effect is amplified. By varying the carbon content, the researchers could tune which mechanism dominated. Low-carbon samples relied mainly on dielectrophoresis and showed slower actuation. Higher-carbon samples displayed rapid deformation driven by both forces. A carbon loading of 0.5 percent offered the best balance of speed, strength, and fabrication reliability.

The researchers demonstrated a range of complex behaviors enabled by this material. Robots built from e-MG could stretch by nearly three times their length, rotate in place, bend around corners, and spread out across surfaces. In one test, a snail-like robot jumped over a gap using a rapid sequence of stretch and release. In another, a humanoid-shaped robot swung along a ceiling by gripping and releasing electrodes. Because e-MG is soft, the robots can deform to anchor themselves against walls or climb vertical surfaces using only field stimuli.

To ensure practical utility, the researchers tested the material’s durability and environmental stability. After 10,000 actuation cycles, e-MG continued to perform reliably. Tests in both air and dielectric liquid confirmed consistent behavior across media. The system also remained functional in low-pressure environments designed to mimic space conditions. The use of mineral oil in some tests mimicked reduced gravity and surface friction, showing potential for extraterrestrial applications. The individual components of the material—silicone elastomer, silicone oil, and carbon nanoparticles—are all compatible with known aerospace standards.

The researchers also explored scalability. Miniature versions of the robot, over 4,000 times smaller in volume than their largest counterparts, still displayed the same range of actuation behaviors. This suggests that the material and actuation principles can be applied across different size scales. Potential uses could include navigating narrow spaces, manipulating fragile components, or performing soft contact tasks in confined environments.

By combining a soft, responsive material with remote electrical control, the e-MG system overcomes key limitations of previous wireless soft robotics. It removes the need for internal circuitry, expands the range of deformation patterns, and enables precise actuation using lightweight external components. Its demonstrated ability to morph, grip, and move through contactless stimulation provides a flexible foundation for new robotic platforms. These could be used in biomedical procedures, industrial inspection, or space exploration—where low weight, high adaptability, and remote control are essential.

Berger’s June 19, 2025 Nanowerk spotlight article has more detail and an embedded video of the soft morphing robots, “This video showcases the versatility of electro-morphing gel (e-MG) robots without internal wiring and controlled by external electric fields. A jelly-like humanoid swings across a ceiling using agile limb movements. A snail-inspired robot jumps across a gap by stretching and contracting its soft body. Another robot navigates a narrow channel, anchoring itself to walls to push a cargo ball forward. These demonstrations highlight the adaptability and wireless control of e-MG systems in diverse tasks.

Here’s a link to and a citation for the paper,

Electric Field Driven Soft Morphing Matter by Ciqun Xu, Charl F. J. Faul, Majid Taghavi, Jonathan Rossiter. Advanced Materials DOI: https://doi.org/10.1002/adma.202419077 First published: 12 June 2025

This paper is open access.

‘Jelly’ batteries

Caption: Researchers have developed soft, stretchable ‘jelly batteries’ that could be used for wearable devices or soft robotics, or even implanted in the brain to deliver drugs or treat conditions such as epilepsy. Credit: University of Cambridge

A July 18, 2024 news item on Nanowerk announces bioinspried stretchy batteries from the University of Cambridge,

Researchers have developed soft, stretchable ‘jelly batteries’ that could be used for wearable devices or soft robotics, or even implanted in the brain to deliver drugs or treat conditions such as epilepsy.

The researchers, from the University of Cambridge, took their inspiration from electric eels, which stun their prey with modified muscle cells called electrocytes.

Like electrocytes, the jelly-like materials developed by the Cambridge researchers have a layered structure, like sticky Lego, that makes them capable of delivering an electric current.

A July 17, 2024 University of Cambridge press release (also on EurekAlert), which originated the news item, offers more details,

The self-healing jelly batteries can stretch to over ten times their original length without affecting their conductivity – the first time that such stretchability and conductivity has been combined in a single material. The results are reported in the journal Science Advances.

The jelly batteries are made from hydrogels: 3D networks of polymers that contain over 60% water. The polymers are held together by reversible on/off interactions that control the jelly’s mechanical properties.

The ability to precisely control mechanical properties and mimic the characteristics of human tissue makes hydrogels ideal candidates for soft robotics and bioelectronics; however, they need to be both conductive and stretchy for such applications.

“It’s difficult to design a material that is both highly stretchable and highly conductive, since those two properties are normally at odds with one another,” said first author Stephen O’Neill, from Cambridge’s Yusuf Hamied Department of Chemistry. “Typically, conductivity decreases when a material is stretched.”

“Normally, hydrogels are made of polymers that have a neutral charge, but if we charge them, they can become conductive,” said co-author Dr Jade McCune, also from the Department of Chemistry. “And by changing the salt component of each gel, we can make them sticky and squish them together in multiple layers, so we can build up a larger energy potential.”

Conventional electronics use rigid metallic materials with electrons as charge carriers, while the jelly batteries use ions to carry charge, like electric eels.

The hydrogels stick strongly to each other because of reversible bonds that can form between the different layers, using barrel-shaped molecules called cucurbiturils that are like molecular handcuffs. The strong adhesion between layers provided by the molecular handcuffs allows for the jelly batteries to be stretched, without the layers coming apart and crucially, without any loss of conductivity.

The properties of the jelly batteries make them promising for future use in biomedical implants, since they are soft and mould to human tissue. “We can customise the mechanical properties of the hydrogels so they match human tissue,” said Professor Oren Scherman, Director of the Melville Laboratory for Polymer Synthesis, who led the research in collaboration with Professor George Malliaras from the Department of Engineering. “Since they contain no rigid components such as metal, a hydrogel implant would be much less likely to be rejected by the body or cause the build-up of scar tissue.”

In addition to their softness, the hydrogels are also surprisingly tough. They can withstand being squashed without permanently losing their original shape, and can self-heal when damaged.

The researchers are planning future experiments to test the hydrogels in living organisms to assess their suitability for a range of medical applications.

The research was funded by the European Research Council and the Engineering and Physical Sciences Research Council (EPSRC), part of UK Research and Innovation (UKRI). Oren Scherman is a Fellow of Jesus College, Cambridge.

Here’s a link to and a citation for the paper,

Highly stretchable dynamic hydrogels for soft multilayer electronics by Stephen J. K. O’Neill, Zehuan Huang, Xiaoyi Chen, Renata L. Sala, Jade A. McCune, George G. Malliaras, and Oren A. Scherman. Science Advances 17 Jul 2024 Vol 10, Issue 29 DOI: 10.1126/sciadv.adn5142

This paper appears to be open access.

Shining a light on flurocarbon bonds and robotic ‘soft’ matter research

Both of these news bits are concerned with light for one reason or another.

Rice University (Texas, US) and breaking fluorocarbon bonds

The secret to breaking fluorocarbon bonds is light according to a June 22, 2020 news item on Nanowerk,

Rice University engineers have created a light-powered catalyst that can break the strong chemical bonds in fluorocarbons, a group of synthetic materials that includes persistent environmental pollutants.

A June 22, 2020 Rice University news release (also on EurekAlert), which originated the news item, describes the work in greater detail,

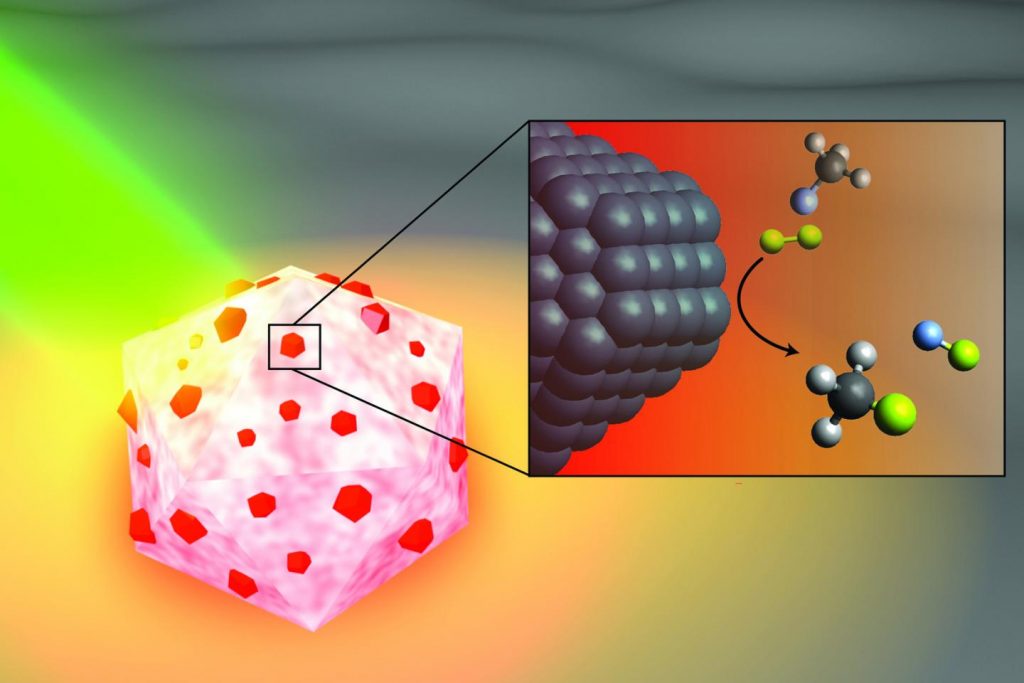
In a study published this month in Nature Catalysis, Rice nanophotonics pioneer Naomi Halas and collaborators at the University of California, Santa Barbara (UCSB) and Princeton University showed that tiny spheres of aluminum dotted with specks of palladium could break carbon-fluorine (C-F) bonds via a catalytic process known as hydrodefluorination in which a fluorine atom is replaced by an atom of hydrogen.

The strength and stability of C-F bonds are behind some of the 20th century’s most recognizable chemical brands, including Teflon, Freon and Scotchgard. But the strength of those bonds can be problematic when fluorocarbons get into the air, soil and water. Chlorofluorocarbons, or CFCs, for example, were banned by international treaty in the 1980s after they were found to be destroying Earth’s protective ozone layer, and other fluorocarbons were on the list of “forever chemicals” targeted by a 2001 treaty.

“The hardest part about remediating any of the fluorine-containing compounds is breaking the C-F bond; it requires a lot of energy,” said Halas, an engineer and chemist whose Laboratory for Nanophotonics (LANP) specializes in creating and studying nanoparticles that interact with light.

Over the past five years, Halas and colleagues have pioneered methods for making “antenna-reactor” catalysts that spur or speed up chemical reactions. While catalysts are widely used in industry, they are typically used in energy-intensive processes that require high temperature, high pressure or both. For example, a mesh of catalytic material is inserted into a high-pressure vessel at a chemical plant, and natural gas or another fossil fuel is burned to heat the gas or liquid that’s flowed through the mesh. LANP’s antenna-reactors dramatically improve energy efficiency by capturing light energy and inserting it directly at the point of the catalytic reaction.

In the Nature Catalysis study, the energy-capturing antenna is an aluminum particle smaller than a living cell, and the reactors are islands of palladium scattered across the aluminum surface. The energy-saving feature of antenna-reactor catalysts is perhaps best illustrated by another of Halas’ previous successes: solar steam. In 2012, her team showed its energy-harvesting particles could instantly vaporize water molecules near their surface, meaning Halas and colleagues could make steam without boiling water. To drive home the point, they showed they could make steam from ice-cold water.

The antenna-reactor catalyst design allows Halas’ team to mix and match metals that are best suited for capturing light and catalyzing reactions in a particular context. The work is part of the green chemistry movement toward cleaner, more efficient chemical processes, and LANP has previously demonstrated catalysts for producing ethylene and syngas and for splitting ammonia to produce hydrogen fuel.

Study lead author Hossein Robatjazi, a Beckman Postdoctoral Fellow at UCSB who earned his Ph.D. from Rice in 2019, conducted the bulk of the research during his graduate studies in Halas’ lab. He said the project also shows the importance of interdisciplinary collaboration.

“I finished the experiments last year, but our experimental results had some interesting features, changes to the reaction kinetics under illumination, that raised an important but interesting question: What role does light play to promote the C-F breaking chemistry?” he said.

The answers came after Robatjazi arrived for his postdoctoral experience at UCSB. He was tasked with developing a microkinetics model, and a combination of insights from the model and from theoretical calculations performed by collaborators at Princeton helped explain the puzzling results.

“With this model, we used the perspective from surface science in traditional catalysis to uniquely link the experimental results to changes to the reaction pathway and reactivity under the light,” he said.

The demonstration experiments on fluoromethane could be just the beginning for the C-F breaking catalyst.

“This general reaction may be useful for remediating many other types of fluorinated molecules,” Halas said.

Caption: An artist’s illustration of the light-activated antenna-reactor catalyst Rice University engineers designed to break carbon-fluorine bonds in fluorocarbons. The aluminum portion of the particle (white and pink) captures energy from light (green), activating islands of palladium catalysts (red). In the inset, fluoromethane molecules (top) comprised of one carbon atom (black), three hydrogen atoms (grey) and one fluorine atom (light blue) react with deuterium (yellow) molecules near the palladium surface (black), cleaving the carbon-fluorine bond to produce deuterium fluoride (right) and monodeuterated methane (bottom). Credit: H. Robatjazi/Rice University

Here’s a link to and a citation for the paper,

Plasmon-driven carbon–fluorine (C(sp3)–F) bond activation with mechanistic insights into hot-carrier-mediated pathways by Hossein Robatjazi, Junwei Lucas Bao, Ming Zhang, Linan Zhou, Phillip Christopher, Emily A. Carter, Peter Nordlander & Naomi J. Halas. Nature Catalysis (2020) DOI: https://doi.org/10.1038/s41929-020-0466-5 Published: 08 June 2020

This paper is behind a paywall.

Northwestern University (Illinois, US) brings soft robots to ‘life’

This June 22, 2020 news item on ScienceDaily reveals how scientists are getting soft robots to mimic living creatures,

Northwestern University researchers have developed a family of soft materials that imitates living creatures.

When hit with light, the film-thin materials come alive — bending, rotating and even crawling on surfaces.

A June 22, 2020 Northwestern University news release (also on EurekAlert) by Amanda Morris, which originated the news item, delves further into the details,

Called “robotic soft matter by the Northwestern team,” the materials move without complex hardware, hydraulics or electricity. The researchers believe the lifelike materials could carry out many tasks, with potential applications in energy, environmental remediation and advanced medicine.

“We live in an era in which increasingly smarter devices are constantly being developed to help us manage our everyday lives,” said Northwestern’s Samuel I. Stupp, who led the experimental studies. “The next frontier is in the development of new science that will bring inert materials to life for our benefit — by designing them to acquire capabilities of living creatures.”

The research will be published on June 22 [2020] in the journal Nature Materials.

Stupp is the Board of Trustees Professor of Materials Science and Engineering, Chemistry, Medicine and Biomedical Engineering at Northwestern and director of the Simpson Querrey Institute He has appointments in the McCormick School of Engineering, Weinberg College of Arts and Sciences and Feinberg School of Medicine. George Schatz, the Charles E. and Emma H. Morrison Professor of Chemistry in Weinberg, led computer simulations of the materials’ lifelike behaviors. Postdoctoral fellow Chuang Li and graduate student Aysenur Iscen, from the Stupp and Schatz laboratories, respectively, are co-first authors of the paper.

Although the moving material seems miraculous, sophisticated science is at play. Its structure comprises nanoscale peptide assemblies that drain water molecules out of the material. An expert in materials chemistry, Stupp linked the peptide arrays to polymer networks designed to be chemically responsive to blue light.

When light hits the material, the network chemically shifts from hydrophilic (attracts water) to hydrophobic (resists water). As the material expels the water through its peptide “pipes,” it contracts — and comes to life. When the light is turned off, water re-enters the material, which expands as it reverts to a hydrophilic structure.

This is reminiscent of the reversible contraction of muscles, which inspired Stupp and his team to design the new materials.

“From biological systems, we learned that the magic of muscles is based on the connection between assemblies of small proteins and giant protein polymers that expand and contract,” Stupp said. “Muscles do this using a chemical fuel rather than light to generate mechanical energy.”

For Northwestern’s bio-inspired material, localized light can trigger directional motion. In other words, bending can occur in different directions, depending on where the light is located. And changing the direction of the light also can force the object to turn as it crawls on a surface.

Stupp and his team believe there are endless possible applications for this new family of materials. With the ability to be designed in different shapes, the materials could play a role in a variety of tasks, ranging from environmental clean-up to brain surgery.

“These materials could augment the function of soft robots needed to pick up fragile objects and then release them in a precise location,” he said. “In medicine, for example, soft materials with ‘living’ characteristics could bend or change shape to retrieve blood clots in the brain after a stroke. They also could swim to clean water supplies and sea water or even undertake healing tasks to repair defects in batteries, membranes and chemical reactors.”

Fascinating, eh? No batteries, no power source, just light to power movement. For the curious, here’s a link to and a citation for the paper,

Supramolecular–covalent hybrid polymers for light-activated mechanical actuation by Chuang Li, Aysenur Iscen, Hiroaki Sai, Kohei Sato, Nicholas A. Sather, Stacey M. Chin, Zaida Álvarez, Liam C. Palmer, George C. Schatz & Samuel I. Stupp. Nature Materials (2020) DOI: https://doi.org/10.1038/s41563-020-0707-7 Published: 22 June 2020

This paper is behind a paywall.

Popcorn-powered robots

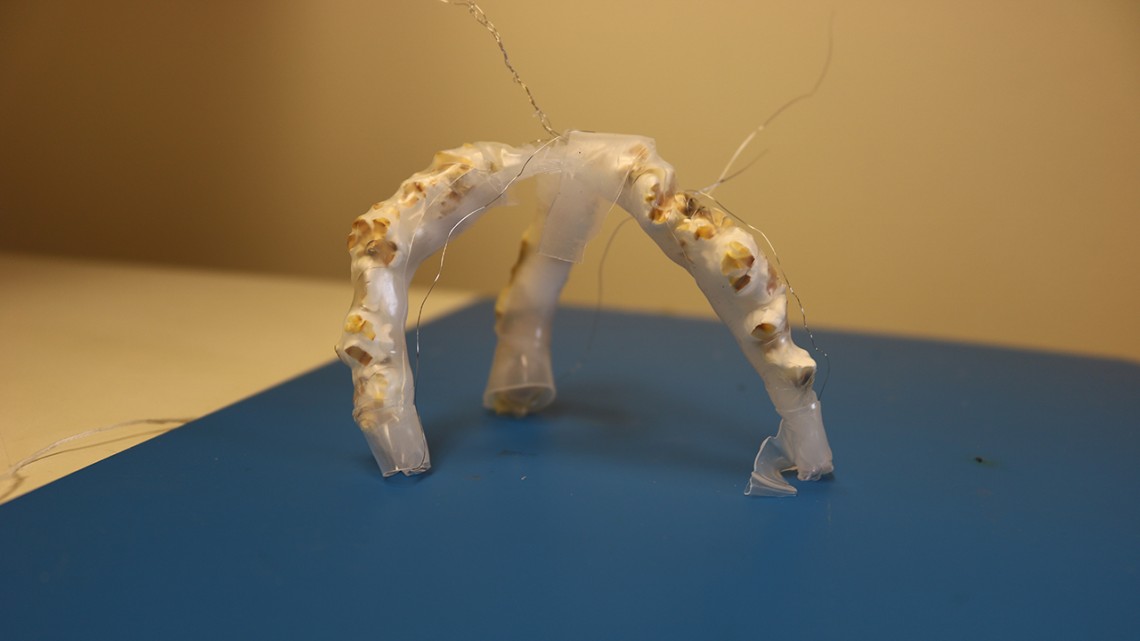
A soft robotic device powered by popcorn, constructed by researchers in Cornell’s Collective Embodied Intelligence Lab. Courtesy: Cornell University

What an intriguing idea, popcorn-powered robots, and one I have difficulty imagining even with the help of the image above. A July 26, 2018 Cornell University news release (an edited version is on EurekAlert) by Melanie Lefkowitz describes the concept,

Cornell researchers have discovered how to power simple robots with a novel substance that, when heated, can expand more than 10 times in size, change its viscosity by a factor of 10 and transition from regular to highly irregular granules with surprising force.

You can also eat it with a little butter and salt.

“Popcorn-Driven Robotic Actuators,” a recent paper co-authored by doctoral student Steven Ceron, mechanical engineering, and Kirstin H. Petersen, assistant professor of electrical and computer engineering, examines how popcorn’s unique qualities can power inexpensive robotic devices that grip, expand or change rigidity.

“The goal of our lab is to try to make very minimalistic robots which, when deployed in high numbers, can still accomplish great things,” said Petersen, who runs Cornell’s Collective Embodied Intelligence Lab. “Simple robots are cheap and less prone to failures and wear, so we can have many operating autonomously over a long time. So we are always looking for new and innovative ideas that will permit us to have more functionalities for less, and popcorn is one of those.”

The study is the first to consider powering robots with popcorn, which is inexpensive, readily available, biodegradable and of course, edible. Since kernels can expand rapidly, exerting force and motion when heated, they could potentially power miniature jumping robots. Edible devices could be ingested for medical procedures. The mix of hard, unpopped granules and lighter popped corn could replace fluids in soft robots without the need for air pumps or compressors.

“Pumps and compressors tend to be more expensive, and they add a lot of weight and expense to your robot,” said Ceron, the paper’s lead author. “With popcorn, in some of the demonstrations that we showed, you just need to apply voltage to get the kernels to pop, so it would take all the bulky and expensive parts out of the robots.”

Since kernels can’t shrink once they’ve popped, a popcorn-powered mechanism can generally be used only once, though multiple uses are conceivable because popped kernels can dissolve in water, Ceron said.

The researchers experimented with Amish Country Extra Small popcorn, which they chose because the brand did not use additives. The extra-small variety had the highest expansion ratio of those they tested.

After studying popcorn’s properties using different types of heating, the researchers constructed three simple robotic actuators – devices used to perform a function.

For a jamming actuator, 36 kernels of popcorn heated with nichrome wire were used to stiffen a flexible silicone beam. For an elastomer actuator, they constructed a three-fingered soft gripper, whose silicone fingers were stuffed with popcorn heated by nichrome wire. When the kernels popped, the expansion exerted pressure against the outer walls of the fingers, causing them to curl. For an origami actuator, they folded recycled Newman’s Own organic popcorn bags into origami bellows folds, filled them with kernels and microwaved them. The expansion of the kernels was strong enough to support the weight of a nine-pound kettlebell.

The paper was presented at the IEEE [Institute of Electrical and Electronics Engineers] International Conference on Robotics and Automation in May and co-authored with Aleena Kurumunda ’19, Eashan Garg ’20, Mira Kim ’20 and Tosin Yeku ’20. Petersen said she hopes it inspires researchers to explore the possibilities of other nontraditional materials.

“Robotics is really good at embracing new ideas, and we can be super creative about what we use to generate multifunctional properties,” she said. “In the end we come up with very simple solutions to fairly complex problems. We don’t always have to look for high-tech solutions. Sometimes the answer is right in front of us.”

The work was supported by the Cornell Engineering Learning Initiative, the Cornell Electrical and Computer Engineering Early Career Award and the Cornell Sloan Fellowship.

Here’s a link to and a citation for the paper,

Popcorn-Driven Robotic Actuators by Steven Ceron, Aleena Kurumunda, Eashan Garg, Mira Kim, Tosin Yeku, and Kirstin Petersen. Presented at the IEEE International Conference on Robotics and Automation held in May 21-25, 2018 in Brisbane, Australia.

The researchers have made this video demonstrating the technology,

3D printing soft robots and flexible electronics with metal alloys

This research comes from Purdue University (Indiana, US) which seems to be on a publishing binge these days. From an April 7, 2015 news item on Nanowerk,

New research shows how inkjet-printing technology can be used to mass-produce electronic circuits made of liquid-metal alloys for “soft robots” and flexible electronics.

Elastic technologies could make possible a new class of pliable robots and stretchable garments that people might wear to interact with computers or for therapeutic purposes. However, new manufacturing techniques must be developed before soft machines become commercially feasible, said Rebecca Kramer, an assistant professor of mechanical engineering at Purdue University.

“We want to create stretchable electronics that might be compatible with soft machines, such as robots that need to squeeze through small spaces, or wearable technologies that aren’t restrictive of motion,” she said. “Conductors made from liquid metal can stretch and deform without breaking.”

A new potential manufacturing approach focuses on harnessing inkjet printing to create devices made of liquid alloys.

“This process now allows us to print flexible and stretchable conductors onto anything, including elastic materials and fabrics,” Kramer said.

An April 7, 2015 Purdue University news release (also on EurekAlert) by Emil Venere, which originated the news item, expands on the theme,

A research paper about the method will appear on April 18 [2015] in the journal Advanced Materials. The paper generally introduces the method, called mechanically sintered gallium-indium nanoparticles, and describes research leading up to the project. It was authored by postdoctoral researcher John William Boley, graduate student Edward L. White and Kramer.

A printable ink is made by dispersing the liquid metal in a non-metallic solvent using ultrasound, which breaks up the bulk liquid metal into nanoparticles. This nanoparticle-filled ink is compatible with inkjet printing.

“Liquid metal in its native form is not inkjet-able,” Kramer said. “So what we do is create liquid metal nanoparticles that are small enough to pass through an inkjet nozzle. Sonicating liquid metal in a carrier solvent, such as ethanol, both creates the nanoparticles and disperses them in the solvent. Then we can print the ink onto any substrate. The ethanol evaporates away so we are just left with liquid metal nanoparticles on a surface.”

After printing, the nanoparticles must be rejoined by applying light pressure, which renders the material conductive. This step is necessary because the liquid-metal nanoparticles are initially coated with oxidized gallium, which acts as a skin that prevents electrical conductivity.

“But it’s a fragile skin, so when you apply pressure it breaks the skin and everything coalesces into one uniform film,” Kramer said. “We can do this either by stamping or by dragging something across the surface, such as the sharp edge of a silicon tip.”

The approach makes it possible to select which portions to activate depending on particular designs, suggesting that a blank film might be manufactured for a multitude of potential applications.

“We selectively activate what electronics we want to turn on by applying pressure to just those areas,” said Kramer, who this year was awarded an Early Career Development award from the National Science Foundation, which supports research to determine how to best develop the liquid-metal ink.

The process could make it possible to rapidly mass-produce large quantities of the film.

Future research will explore how the interaction between the ink and the surface being printed on might be conducive to the production of specific types of devices.

“For example, how do the nanoparticles orient themselves on hydrophobic versus hydrophilic surfaces? How can we formulate the ink and exploit its interaction with a surface to enable self-assembly of the particles?” she said.

The researchers also will study and model how individual particles rupture when pressure is applied, providing information that could allow the manufacture of ultrathin traces and new types of sensors.

Here’s a link to and a citation for the paper,

Nanoparticles: Mechanically Sintered Gallium–Indium Nanoparticles by John William Boley, Edward L. White and Rebecca K. Kramer. Advanced Materials Volume 27, Issue 14, page 2270, April 8, 2015 DOI: 10.1002/adma.201570094 Article first published online: 7 APR 2015

© 2015 WILEY-VCH Verlag GmbH & Co. KGaA, Weinheim

This article is behind a paywall.